

The gap between a robot that welds and a robot that welds well comes down to programming decisions most operators don’t even know they’re making wrong. Simple choices about motion types, torch positioning, and parameter testing separate efficient, quality production from constant rework and scrap.
You can destroy an entire batch with a single programming mistake. Improper travel speed causing distortion, poor welding parameters producing excessive spatter, or inefficient air moves killing your cycle time. Even with a premium welding robot and power source, bad programming turns automation into a liability.
This guide covers the programming best practices that have the highest impact on weld quality, cycle time, and long-term system performance. Let’s dive into immediate fixes and go to foundational system design decisions from there.
Best Practices For Immediate Robotic Welding Programming Improvement
Many programming problems come down to a handful of high-impact mistakes that compound across every part you weld. Fix these first, and you’ll see immediate improvements in cycle time, weld quality, and program reliability.
1. Keep Welding Programs Simple
Complex programs with nested processes, excessive conditional logic, and overcomplicated motion sequences create multiple problems:
- Harder to troubleshoot
- Slower to modify
- More prone to failure
- Reduce production efficiency through compounded movement delays
Break complex welds into simple subroutines. If you can’t explain a program in three sentences, it’s too complicated.
2. Program for Real-World Conditions

Your production floor has fixtures that block ideal torch angles, clamps in inconvenient locations, and parts that don’t always sit exactly where they should.
Walk through the actual production environment before finalizing programs.
Consider how parts actually behave under real conditions and if the robot movement is adequate.
3. Use Non-Linear Moves for Efficiency
Non-linear moves (joint moves) allow the robot to take the fastest path between positions by moving all axes simultaneously. Linear moves force the robot to move along one axis for precision.
Use non-linear moves for all air movements between welds and linear moves only for the actual weld path or when collision avoidance requires precise trajectory control.
This single change can cut cycle time by 10-20% or more depending on your parts.
4. Optimize Air Move Speed
Most programmers leave air moves at default speeds, wasting seconds on every cycle.
Increase air move velocity to 80-100% of maximum for movements with clear paths.
Slow down only when approaching tight spaces or near collision zones.
5. Use Approach and Retract Functions Properly
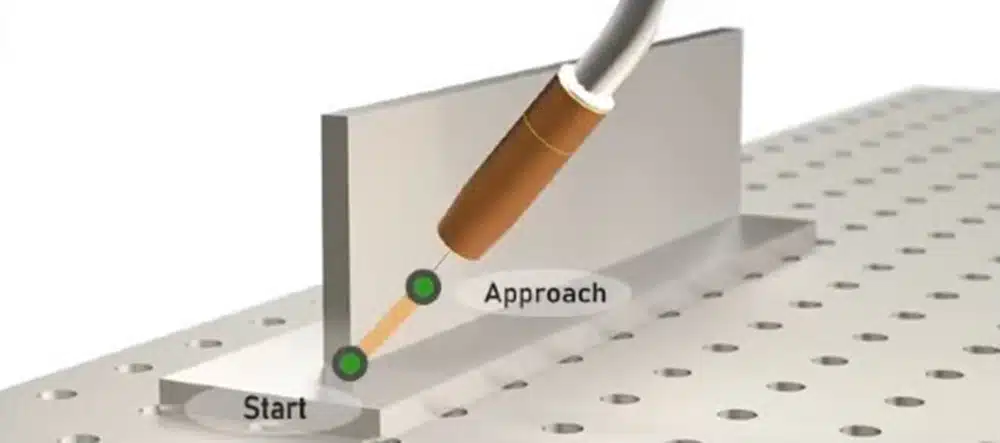
Use the built-in approach and retract functions instead of separate air moves to position the torch before and after welding. These reduce program complexity and ensure consistent standoff distance.
Unless there’s a reason not to, you should also maximize the approach/retract speed variable to additionally compound time savings.costs. Usually, the more sophisticated the process, the more costly the equipment.
6. Manage Travel Speed for Thermal Control
Excessive travel speed causes:
- Lack of fusion
- Cold laps
- Undercut
- Porosity and poor gas shielding
- Whiskers at the bottom of the root (mostly in MIG welding)
- Underfill.
Too slow leads to:
- Excessive heat input
- Burn-through
- Distortion
- Heat tint and oxidation of sensitive alloys.
Start with proven manual welding parameters and match robot travel speed to your established wire feed speed and voltage.
Don’t let the robot run faster just because it can, or underutilize its speed. The trick to quality welding with high travel speed is testing various speed programming and using the best combination for your part.
7. Optimize Weld Sequence to Minimize Distortion
Welding order matters as much as individual weld quality. Continuous welds on one side of a part create uneven thermal expansion and permanent warping.
Program intermittent welding patterns, alternate sides, or work from the center outward to balance heat distribution.
On complex weldments, simulate thermal effects before committing to a sequence.
8. Avoid Singularities and Collision Paths
Singularities occur when the robot’s axes align in ways that make motion impossible. The robot may slow dramatically, stop, or move erratically.
Review programs in simulation mode to identify potential singularities and adjust approach angles or wrist positioning.
Similarly, verify that air moves don’t create collision risks with fixtures, parts, or the worktable.
9. Validate Tool Center Point (TCP)
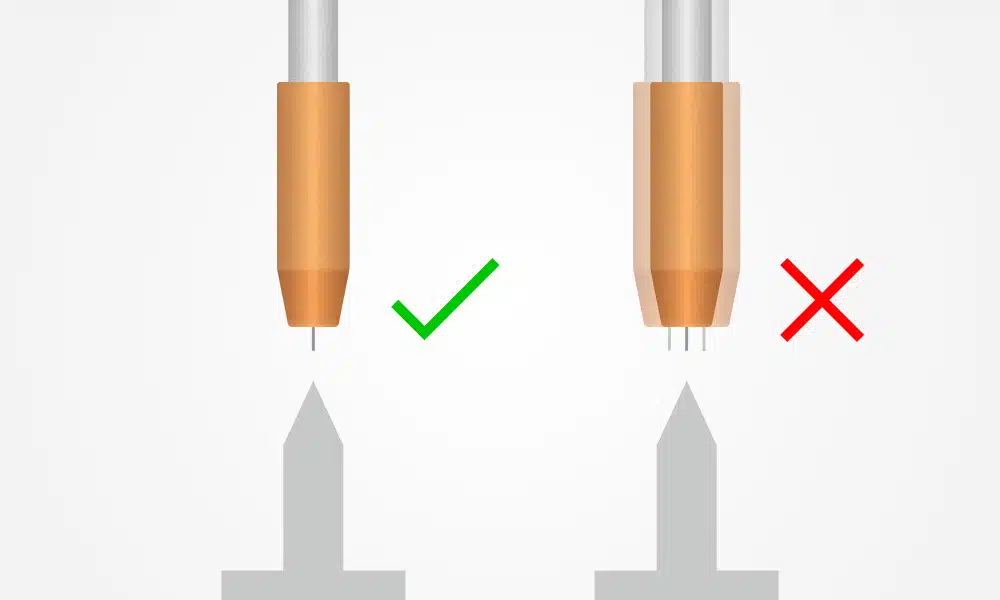
An incorrect TCP means the robot thinks the torch tip is in a different location than reality, causing positioning errors that compound across the entire weld path.
Recalibrate TCP whenever you change consumables, after torch crashes, or when welds don’t land where expected.
Pay particular care to understand the specifics of TCP programming for your robot and the software you use.
10. Test in Simulation Before Running Production
Simulation mode lets you validate motion paths, check for collisions, and verify cycle time without striking an arc.
Use it for every new program, not just complex ones.
Catch singularities, collision risks, and reach limitations before wasting production time and materials.
11. Iterate on Welding Parameters, Not Just Motion
Many programmers obsess over robot positioning while ignoring the welding process itself. Your wire feed speed, voltage, contact-tip-to-work distance, and shielding gas flow directly determine weld quality.
Test parameter variations systematically and document what works.
How Your System Design Affects Welding Programming
Programming and system design are interdependent.
- The hardware you choose
- How you arrange your cell
- Fixture selection and use
- Auxiliary equipment you include
- Welding features of your power source
- The operator and robot co-op welding practices
All directly determine what’s possible in your programs and how complex those programs need to be.
Design Beyond the Flat Table
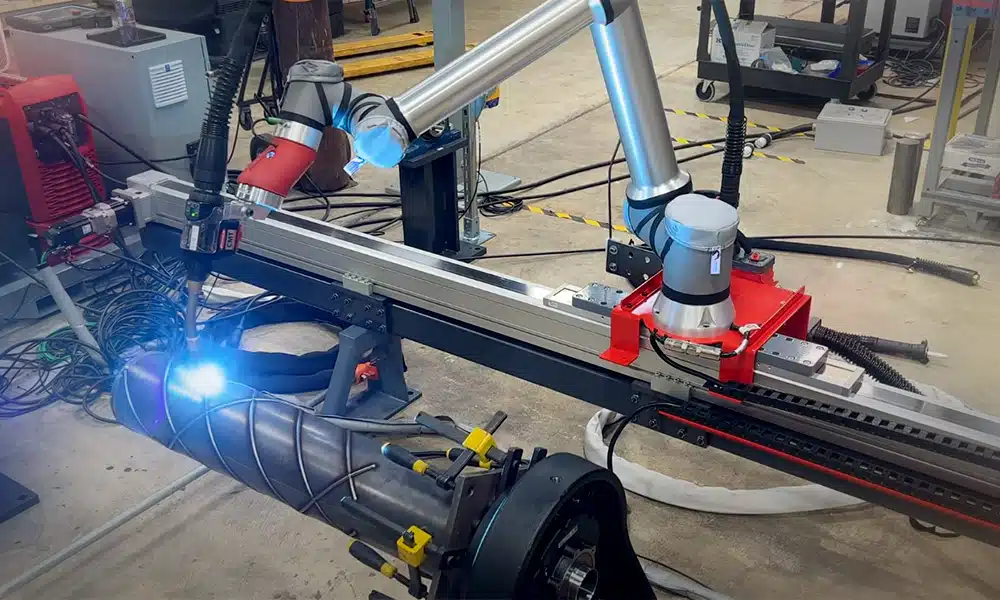
A standard welding table only allows programming relatively simple parts. Anything more complex and you are dealing with significant inefficiencies.
Positioners, turntables, and track systems bring welds into the robot’s optimal working envelope, simplifying programs and cutting cycle time.
The best weld position isn’t always the easiest loading position. External motion solves that problem.
Build in Adaptive Capabilities for Part Variation

Real parts don’t always match CAD models. Tolerance stack-up, fit-up gaps, and material inconsistencies mean your perfectly programmed path may miss the joint.
Visual seam tracking and systems like Fronius Wire Sense automatically compensate for part variation without manual program adjustments.
This keeps programs simple while handling real-world conditions.
Match Process Technology to Programming Requirements
Advanced welding processes change what’s possible in your programs.
- CMT (Cold Metal Transfer) reduces spatter and heat input. It enables welding on thin materials at slower, more controlled speeds. It can also achieve faster travel on thicker sections with better penetration and less distortion.
- Pulsed MIG offers similar benefits for different applications.
These aren’t just “nice to have” features. They fundamentally alter your programming options and what parts you can successfully automate.
Design for Hybrid Workflows
Dividing your worktable into robotic and manual zones maximizes system utilization.
While the robot welds one fixture, an operator can load, inspect, or perform secondary operations on another. Simultaneous operation can be achieved with a safety wall separation, programming, or with a collaborative application.
Integrate Automated Maintenance
Torch cleaning and wire cut stations prevent weld defects from spatter buildup and inconsistent wire stick-out.
Program cleaning cycles at strategic intervals, not after every weld (wastes time).
Most systems need cleaning every 3-10 welds, depending on weld lengths, spatter, welded metal, and many other factors.
Understand Equipment Dependencies
Programs aren’t universally transferable. A program developed with one power source may fail with another because it relied on specific arc control features, communication protocols, or timing sequences.
The arc control behavior and functions can vary by power source brands.
Document equipment dependencies and test thoroughly when changing hardware.
Choosing Your Welding Robot Programming Type
Modern robotic welding has evolved beyond the complexity that once required dedicated robotics engineers. The right system choice determines whether programming becomes an accessible skill for your welding team or remains a specialized bottleneck.
Traditional Industrial Robots vs Modern Collaborative Robotic Applications
Traditional industrial robots require text-based programming languages specific to each manufacturer. This creates a steep learning curve and dependencies on specialized programmers.
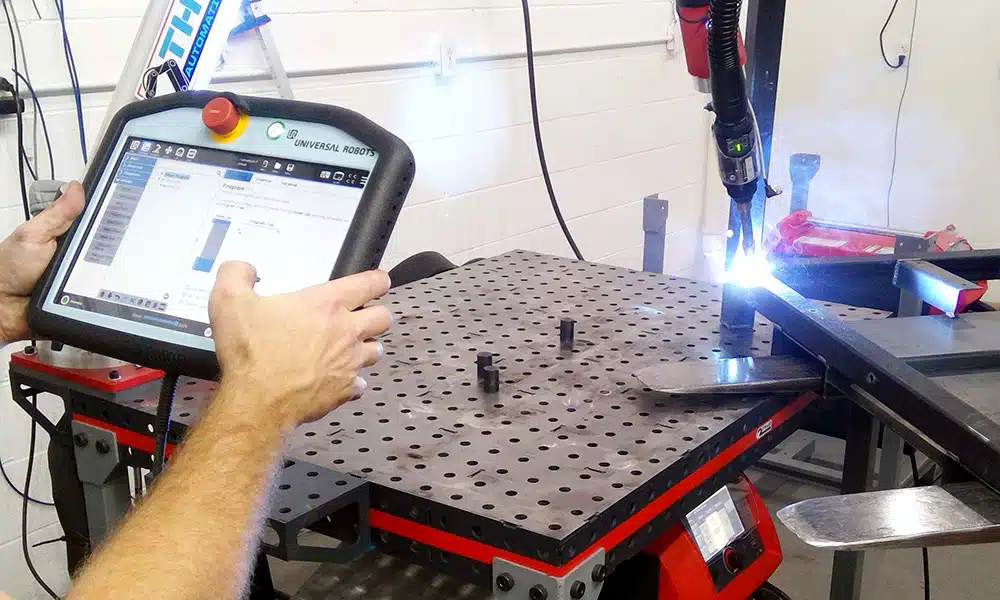
Modern robotics capable of collaborative applications use intuitive teach pendants with graphical interfaces, allowing welders to program by physically guiding the robot through desired positions.
Industrial robotics that supports collaborative applications between an operator and a robot are popularly known as “cobots.” They can operate without safety cages and require significantly easier programming, making it far simpler to get the programming right.
However, the scope and ability to design a collaborative application depends on various production factors and must pass a safety assessment for industrial robots. See ISO 10218-2:2025, Robotics — Safety requirements for more details.
Robotic Welding Programming Software and Brand Differences
Each robot manufacturer provides proprietary programming software with distinct interfaces and logic structures. For example:
- ABB: RobotStudio with integrated arc welding PowerPacs
- Fanuc: Roboguide for offline programming, teach pendant for online
- KUKA: WorkVisual and KUKA.Sim for offline development
- Universal Robots (cobot): UR Polyscope with visual programming interface
These aren’t just different names for the same thing. Each uses different coordinate systems, motion types, and welding-specific functions.
Programs aren’t portable between brands. Your choice locks you into that manufacturer’s ecosystem, so consider long-term support, available training, and whether your team can realistically master that specific platform.
Offline Programming vs Teach Pendant Programming
Offline programming uses computer simulation to create programs away from the production floor, then downloads them to the robot. This maximizes robot uptime. It’s critical for high-volume operations where every minute of downtime costs money.
For high-mix, low-volume job shops, teach pendant programming often makes more sense. You’re constantly switching between different parts with unique fixtures and positioning. The overhead of building accurate digital twins, maintaining CAD models, and validating programs in simulation outweighs the time saved.
Pendant programming lets you adapt quickly to real-world conditions, adjust for part variation on the fly, and validate programs immediately.
Offline programming has value for complex parts, collision detection, and cycle time optimization, but it shouldn’t be the default assumption for every shop.
Skills Needed for Welding Robot Programming
With the right robotic system, your experienced welders become your best programmers. You need welding skills first, programming skills second.
The robot doesn’t make better welds, it repeats the welds you teach it. If you don’t understand proper travel speed, torch angle, heat input, and how to read weld defects, no amount of programming expertise will create quality parts.
Start with people who know welding processes, joint design, and metallurgy. Have them learn how to program welds with intuitive graphical software without coding.
As Zach Van Meter, Owner/Operator at TMF Center puts it:
“We want to give employees a third arm – more power, more ownership, more time to be yourself, and less time where you have to follow a repetitive operation.”
This is the direction much of the industry is heading. Unless you are into serial production, focus on robotic systems that require welding skills first. You don’t have to write any lines of code.
How to Learn Robotic Welding Programming for Beginners
Real-world experience beats classroom theory. Start with simple, forgiving applications:
- Short linear welds with consistent joint access
- Parts that tolerate minor positioning errors
- Repeatable fixtures that don’t require complex programming logic
Modern cobot systems with intuitive interfaces let beginners focus on welding fundamentals rather than coding syntax or complex CAD software. You don’t need engineering degrees or months of training—just welding knowledge, patience to learn the teach pendant, and willingness to iterate on programs until they work reliably.
How To Program A Welding Robot: Practical Examples
Now, let’s jump into the actual meat and potatoes. The THG Automation uses Polyscope software from Universal Robots to program welds in all of our robotic welding systems. It doesn’t require code, and you can program everything hands-on in collaborative welding applications. You can program most welds in less than 20 minutes, even if you don’t have any prior robotic experience.
As a quick intro, see this 3-minute video to get a clear idea of just how easy robotic weld programming can be.
Basics: How The Teach Pendant Works
The teach pendant included with all THG robotic welding systems uses a graphical, intuitive software that lets you program a weld without coding. All robotic systems have teach pendants, but not all have an interface where you can program welds without writing code

This is where weld programming starts. You can select functions from the left drop-down menu under Polyscope (once the THG Polyscope is uploaded) such as weld start, weld move, or weld end. Likewise, you can add moves (joint or linear), part check, edge detect, and other functions.
Basics: How To Program A Linear Weld
Linear welds can be programmed quickly. They are the most straightforward, but there are a few tricks to speed up the cycle time and make them more efficient.
First, let’s move the robot arm in the starting position that’s suitable in the context of fixtures and part shape.
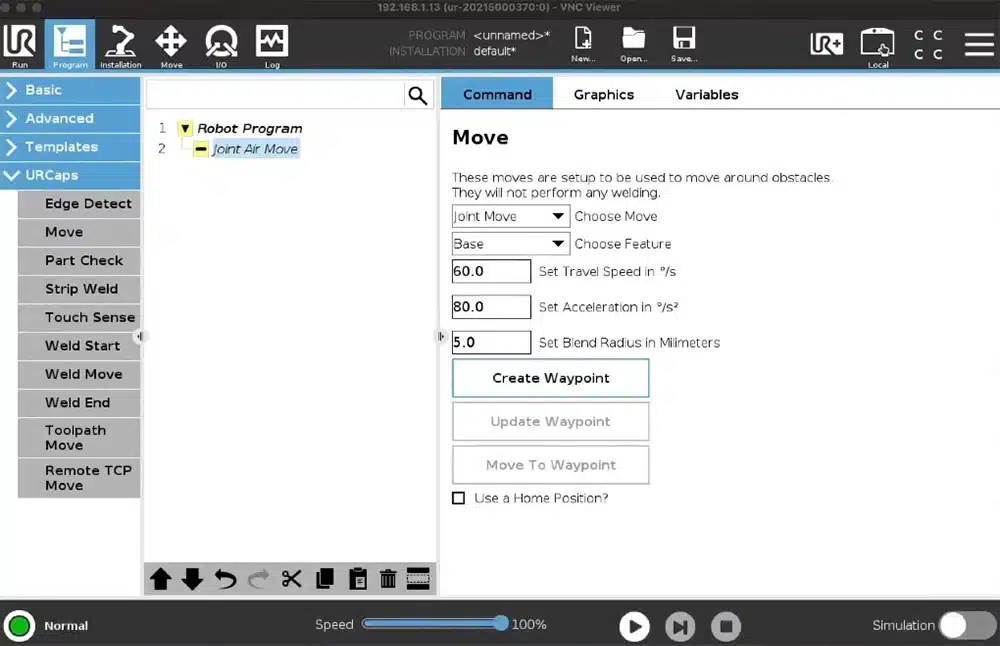
- Tap on the “Move” in the Polyscope dropdown on the left.
- Select the drop-down “Choose Move” and opt for a “Joint Move.” This increases the movement efficiency compared to Linear Move.
- Manually move the robot torch to the starting position.
- Tap on the “Create Waypoint” and press OK after fine-tuning the position (if required).
Now, let’s make a weld path.

- Tap on the “Weld Start” in the dropdown on the left.
- Select “WeldMoveP” and delete it if you don’t need a midpoint.
- Select “Weld Start” in the Robot Program list.
- Manually move the robot torch to the weld start position. This is the actual welding point. This is where welding experience is critical as you need to manually set the right torch angle and tip to work distance for the joint and material type.
- Click “Create Waypoint,” fine-tune, and click OK.
- Select the “Weld End” in the Robot Program and repeat the same process.
- Done.
Finally, let’s make this move more efficient to improve cycle time speed.

- Select “Weld Start” in the Robot Program list.
- Tap on the “Movement Parameters.”
- Adjust the Approach Distance and Approach Travel Speed. This is the distance and speed from the initial air move (joint move) we made in the first step. So, there’s no need to make additional air moves. The approach movement is built into the Weld Start function. Adjust the speed as you see fit for the best cycle time.
- Repeat the same in the “Weld End” for the opposite, Retract Distance and Travel Speed. This eliminates the need for multiple air movements between spaced-out welds, for example.
- At this point, you can also add a Linear or Joint Move to set the torch to a specific spot after the welding sequence is finished.
- Done.
Programming The Robot To Weld With a Positioner
Complex parts, especially with curved/round geometry, are difficult or impossible to program for robotic welding without a positioner. That’s why all THG robotic welding systems come pre-integrated for positioners and Coordinated Motion.
So, if you need to add a positioner later on, it works seamlessly using the simple programming steps as shown below:
- Start with a new program in the Polyscope software.
- Select the “Position Mode” in the “Polyscope” dropdown menu.
- Click on “Weld Start.”
- Select the middle of the “Weld Start” and add another “Position Mode.”
- Remove the “WeldMoveP” if you don’t need the middle point.
- Select your first “Position Mode” and input your degrees (0 for the start).
- Select your second “Position Mode” and input your degrees (360 for the end).
- Set the part diameter dimension (in the second “Position Mode”).
- Adjust travel speed for the thickness and material (in the second “Position Mode”).
- Done.
See the video for visual instructions:
Simplify Robotic Welding Programming With THG Automation
Programming complexity shouldn’t hold back your automation goals. THG Automation designs robotic welding systems specifically to reduce programming barriers while maintaining industrial-grade performance and future expansion.
Pre-integrated systems eliminate compatibility issues. When your robot, power source, positioners, and control software are engineered to work together, you avoid the workarounds and troubleshooting that plague multi-vendor setups. Programs work consistently across your entire system because every component communicates properly.
Modular design grows with your needs. A simple system works today, but what happens when you are ready to grow with a multi-process capability, external axes, or adaptive control? THG’s platform lets you add capabilities without re-learning programming workflows. Your future programs remain as simple as today’s, even as your system becomes more sophisticated.
Adaptive control handles real-world variation. Fronius Wire Sense technology automatically adjusts parameters when torch height varies, compensating for part inconsistencies and fit-up gaps without manual program modifications. This keeps your programs simple while handling the imperfect conditions of production welding.
Ready to see how THG systems can work with your parts? Talk to our fabrication experts, and explore THG system configurations designed around practical programming workflows.